Key Takeaways
Quick Answer: CAN bus allows a vehicle-mounted rugged tablet to communicate with electronic control units inside a vehicle network. In fleet, agriculture, mining, forklift, public-safety, and heavy-equipment deployments, rugged tablets use CAN communication for diagnostics, telematics, engine monitoring, driver workflow integration, and vehicle data collection.
- CAN bus rugged tablets connect a vehicle-mounted rugged tablet to vehicle electronic control units for diagnostics, telematics, condition monitoring, and workflow automation.
- Before rollout, buyers must validate the CAN protocol, CAN 2.0 or CAN FD support, J1939 or OBD-II access, vehicle voltage range, grounding, docking stability, and software integration.
- Fleet transport, forklifts, agriculture, mining, construction, and public safety vehicles use CAN bus data such as RPM, ignition status, fuel level, vehicle speed, PTO status, and fault codes.
- Unstable power, poor grounding, vibration, EMI, and loose mounts are common reasons CAN communication fails in real vehicles, even when a lab test works.
- KCOSIT vehicle-mounted rugged tablet, docking, and mounting configurations can be evaluated for CAN-focused vehicle integration projects based on the target vehicle network, software stack, power design, and deployment environment.
For industrial deployments, buyers must verify protocol compatibility, vehicle voltage, grounding, vibration resistance, docking stability, software support, and ECU access before moving from pilot testing to fleet rollout.
What Is CAN Bus in a Vehicle-Mounted Rugged Tablet?
Quick Answer: CAN bus is the in-vehicle communication backbone that lets a rugged tablet exchange CAN frames with ECUs for diagnostics, telematics and real-time monitoring. Vehicle-mounted rugged tablets use it in fleets, forklifts, agriculture vehicles, mining machines and public safety vehicles, but buyers must validate protocol support, voltage, grounding, docking and software decoding before deployment.
CAN bus, or controller area network, is a message-based vehicle communication protocol that lets electronic control units share short, reliable messages across a common wiring bus. In a rugged tablet deployment, CAN bus rugged tablets join the vehicle CAN network through a built-in CAN interface, a vehicle dock, a CAN gateway, or an external adapter.
Modern cars have dozens of Electronic Control Units (ECUs) connected to the same shared wiring, which communicate through a CAN bus. The CAN bus is widely used in the automotive industry for communication between various Electronic Control Units (ECUs), such as engine control, transmission, and safety systems like airbags and anti-lock brakes, which aligns with how rugged tablets for the automotive industry are used for diagnostics, in-vehicle computing, and production workflows.
At a practical level, a vehicle-mounted rugged tablet reads CAN bus data from the engine control unit, transmission controller, brake controller, body controller, and auxiliary control systems. The CAN bus protocol is a message-based protocol designed to allow Electronic Control Units (ECUs) in vehicles to communicate with each other in a reliable, priority-driven manner, without the need for a host computer.
For rugged tablet buyers, the most important CAN details are not the ISO layer names. The practical checks are the exposed vehicle network, CAN type, baud rate, connector, gateway access, grounding, power stability, and whether the software can decode the required signals.
CAN is also used beyond road vehicles. In industrial automation, CAN bus applications include robotics, factory equipment control, and building automation systems, allowing for efficient communication between devices and centralized control, similar to how rugged tablets support industry-specific solutions across logistics, manufacturing, and field services.
CAN is widely used across many vehicles and mobile machines, but each vehicle platform may expose different networks, gateways, message formats, and access permissions.
How Vehicle-Mounted Rugged Tablets Use CAN Communication
Quick Answer: Rugged MDT tablets use CAN communication to read, log and sometimes transmit data to ECUs for telematics, diagnostics, driver applications and workflow integration. The normal path is tablet to CAN interface, CAN interface to vehicle harness, and vehicle harness to ECUs.
A typical workflow is:
vehicle-mounted rugged tablet ⇄ CAN interface or dock ⇄ vehicle CAN harness ⇄ engine, transmission, ABS, body, and auxiliary ECUs
The rugged tablet is not usually replacing the vehicle controller. It acts as a rugged MDT, telematics tablet, or diagnostic display that receives a data stream, decodes vehicle parameters, and presents useful information to drivers, technicians, or fleet systems.
A CAN frame may include an identifier, data length code, data field, data bytes, cyclic redundancy check, and other control information. In a deployment conversation, the important point is that the application turns a data frame into usable information, such as engine speed, vehicle speed, ignition state, fuel level, PTO engagement, or diagnostic trouble codes.
CAN frames are prioritized by ID, allowing high-priority data to gain immediate access to the bus without causing interruptions to other frames, which enhances the efficiency of data transmission. The CAN protocol uses a lossless bitwise arbitration method for contention resolution, allowing multiple nodes to communicate without data collisions, where the node with the lowest identifier has the highest priority.
This matters in a vehicle because priority data, top priority data, and safety-related messages must not be delayed by lower-value logging traffic. Message priority, bus access and immediate bus access are handled by the bus protocol, so the integrator should avoid adding unnecessary traffic that increases load on a busy CAN network.
Some projects only need read-only monitoring. Others involve requesting data, sending a remote transmission request, or using a calibration protocol for service functions. Write access should be tightly controlled because traditional CAN systems lack native encryption, making them susceptible to hacking or unauthorized manipulation if an attacker gains physical access to the network.
A rugged tablet may connect through an OEM telematics connector, an aftermarket CAN gateway, a diagnostic connector, or a direct connection to the main bus, where OEM guidance allows it. A CAN gateway may bridge multiple networks, such as powertrain CAN, body CAN, implement CAN, and auxiliary equipment CAN.

CAN Bus vs OBD-II vs SAE J1939
Quick Answer: CAN bus is the underlying controller area network technology, OBD-II is a diagnostics standard mainly used in light vehicles, and SAE J1939 is a higher layer protocol over CAN for heavy-duty vehicles and equipment. A CAN bus tablet project must identify which one the vehicle actually exposes.
CAN, OBD-II, and J1939 are often discussed together, but they are not interchangeable. CAN is the communication system and physical/data link foundation; OBD-II defines a diagnostic access model and connector for many light-duty vehicles; J1939 defines heavy-duty vehicle communication using 29-bit identifiers, PGNs, and SPNs.
Many heavy trucks, buses, agricultural machines, and construction vehicles use J1939 over a 250 kbit/s or 500 kbit/s CAN bus. Passenger vehicles often expose OBD-II at the diagnostic port while also using manufacturer-specific CAN inside the vehicle architecture.
The CAN bus supports data rates of up to 1 megabit per second (Mbps) and is structured to handle medium bandwidth requirements, making it suitable for various automotive applications. Classic CAN buses max out at 1 Mbit/s, which can cause bottlenecks in modern, data-heavy systems.
CAN FD, or flexible data rate, is increasingly relevant in newer vehicles and electric platforms. CAN FD (Flexible Data-Rate), standardized as ISO 11898-1, allows for variable data rates during transmission and increases the maximum data payload size from 8 bytes to 64 bytes, enhancing data throughput in modern applications.
CAN FD (Flexible Data-Rate) allows for data rates of up to 5 Mbps, significantly higher than the 1 Mbps maximum of traditional CAN, enhancing data throughput for modern applications. The maximum data payload size in CAN FD has been increased from 8 bytes in traditional CAN to 64 bytes, allowing for more efficient data transmission and reducing the number of frames needed for large data transfers.
CAN FD maintains backward compatibility with CAN 2.0 devices by using the same frame format as CAN 2.0B, enabling coexistence on the same bus while allowing higher data rates and larger payloads when communicating with other CAN FD devices. Buyers should still confirm the actual vehicle network because not every mid-2020s fleet exposure can feed to third-party devices.
CAN vs OBD-II vs SAE J1939
| Technology | What It Is | Typical Vehicle | Buyer Mistake |
|---|---|---|---|
| CAN bus | The underlying vehicle network and CAN bus protocol for ECU communication | Passenger car, van, truck, forklift, tractor, mining vehicle | Assuming raw CAN access means every signal is documented |
| OBD-II on CAN | Diagnostics access standard, often through a 16-pin connector | Light-duty van, service car, pickup | Expecting full body, PTO, or hydraulic data from a limited diagnostics port |
| SAE J1939 | Higher-layer protocols over CAN for heavy-duty vehicles and equipment | 2024 EU heavy truck, bus, tractor, excavator | Ignoring 250 kbit/s or 500 kbit/s settings and required PGN/SPN decoding |
| Mixed fleet network | Multiple CAN channels, gateways, and OEM-specific messages | Municipal fleet with trucks, snow plows, buses, and older equipment | Buying one adapter without validating protocols across vehicle types |
What Vehicle Data Can Rugged Tablets Read from CAN Networks?
Quick Answer: Rugged tablets commonly read RPM, vehicle speed, ignition status, odometer, fuel level, engine load, battery voltage, PTO engagement, hydraulic pressure and fault codes from CAN networks. The tablet software normally works with decoded signals, not raw bus data alone.
Useful vehicle data usually falls into several categories:
- Powertrain: RPM, torque, coolant temperature, oil pressure, fuel rate, engine load, and battery voltage.
- Chassis: brake status, ABS events, wheel speed, transmission data, and vehicle speed.
- Body systems: doors, lights, ignition status, wipers, seats, and auxiliary outputs where access is available.
- Auxiliary systems: PTO, lift height, mast tilt, boom position, hydraulic pressure, and implement data.
- Diagnostics: active and inactive diagnostic trouble codes, SPN/FMI codes, warning states, and maintenance alerts.
The CAN bus provides a centralized point of entry to communicate with all network ECUs, enabling central diagnostics, data logging, and configuration, which simplifies vehicle maintenance and monitoring. The CAN bus is integral to fleet management systems, enabling real-time data collection for GPS tracking, fuel usage monitoring, and maintenance alerts in commercial vehicles like trucks and buses.
In practice, the tablet application rarely displays raw hexadecimal frames to the user. It uses OBD-II PIDs, J1939 PGNs/SPNs, OEM DBC files, or integrator-defined lookup tables to decode CAN bus data into a usable value.
A simple example is: CAN ID + data payload → decoded vehicle speed → driver app, maintenance app, or cloud telematics platform. The same approach can map engine speed, PTO state, or a fault code into a workflow rule.
Technical fields such as start of frame, identifier extension bit, data length, data length code, data bytes, data field, remote frame, and error frame are important to the CAN controller and integration software. For procurement teams, the key question is whether the rugged tablet CAN interface, driver, and API can decode and deliver the required data reliably.
New ECUs and sensors can be added to a CAN network easily without requiring a complete redesign of the electrical architecture. That is one reason CAN remains practical in complex system designs, including vehicles with multiple nodes, multiple networks, bus controllers, and a mix of legacy and newer ECUs.
Read-Only Monitoring vs Control Commands: What Buyers Must Separate
Quick Answer: Most rugged tablet CAN deployments should start with read-only monitoring. Write commands or control functions require OEM approval, security validation, and strict software safeguards.
For fleet management, maintenance, and operator workflows, a rugged tablet often only needs to read vehicle speed, RPM, ignition status, fuel data, fault codes, or equipment state. This lowers integration risk because the tablet is not trying to control ECUs.
Control commands are different. If a tablet sends data onto the CAN bus, the project must define who authorizes the command, which ECU accepts it, how the software prevents accidental transmission, and how the system behaves during power loss, vibration, or app failure.
Procurement teams should separate “read CAN data” from “write to CAN bus” in the RFQ. A supplier may support CAN reading, but write access, calibration functions, or service commands require a much higher validation level.
Fleet, Forklift, Agriculture, and Heavy Equipment CAN Workflows
Quick Answer: Different vehicle types use CAN data differently. On-road fleets focus on telematics and driver behavior, forklifts focus on safety and utilization, agriculture vehicles focus on PTO and implement workflows, and heavy equipment focuses on condition monitoring and uptime.
The same rugged tablet CAN bus connection can support very different field workflows. A fleet rugged tablet in a truck cab may upload fuel use, idling, harsh braking, and fault data to a telematics platform. A forklift CAN tablet may support access control, pre-shift checks, and impact logging.
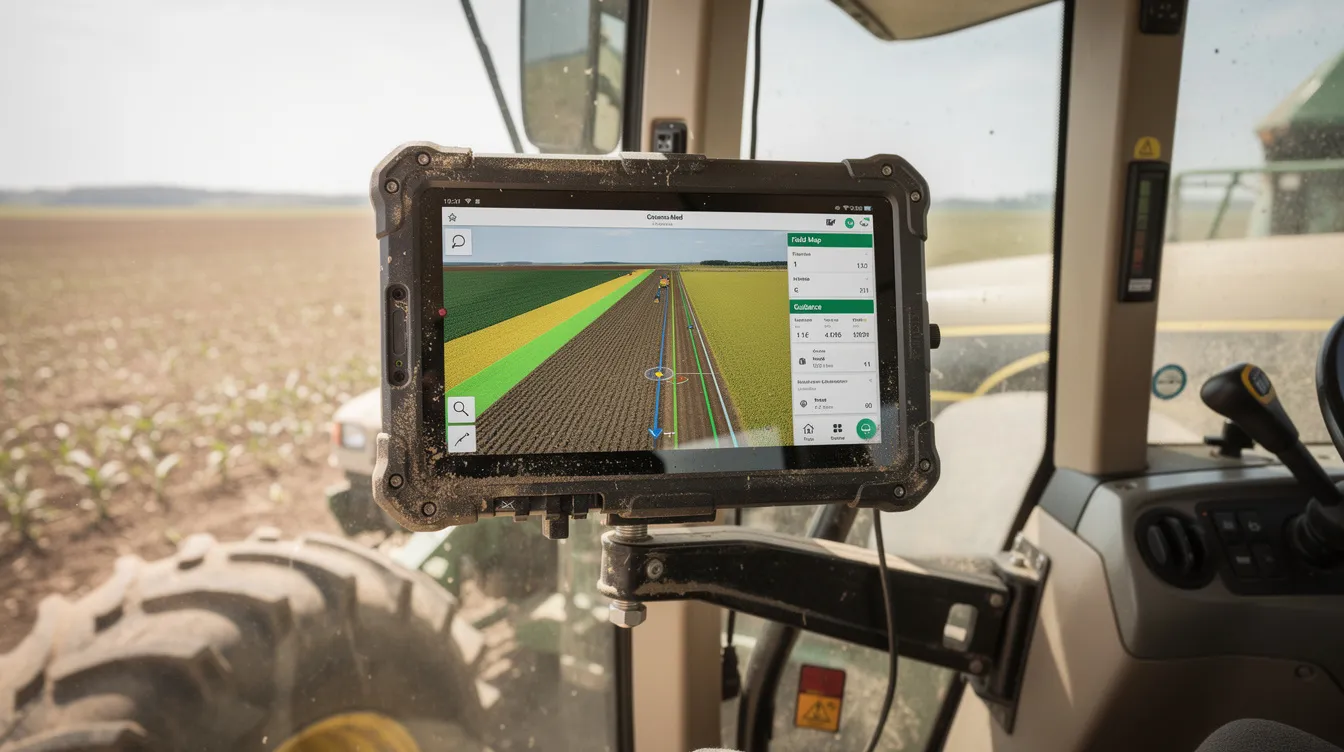
The CAN bus is also utilized in heavy-duty and off-road machinery, such as tractors and construction equipment, for diagnostics and control of various systems, including ISOBUS communication in agriculture. This is why agriculture vehicle tablet and industrial vehicle tablet projects often require J1939 knowledge, GNSS integration, and rugged mounting, especially in rugged tablets for precision farming that rely on accurate GNSS-linked implement workflows.
Vehicle CAN Workflow Matrix
| Vehicle Type | Typical CAN Data | Rugged Tablet Use Case | Deployment Risk |
|---|---|---|---|
| Long-haul Class 8 truck | RPM, fuel use, engine hours, fault codes, vehicle speed | Fleet reporting, driver HMI, maintenance alerts | J1939 configuration, power dips during cranking, gateway filtering |
| City bus | Door state, brake events, engine temperature, odometer | Dispatch, passenger service workflow, diagnostics | Multiple CAN networks and public-safety equipment interference |
| Warehouse forklift | Lift height, mast tilt, impact events, battery status | Safety checklist, access control, and utilization reporting | Vibration, connector wear, and high-current motor noise |
| Combine harvester | PTO, engine load, implement status, yield-related data | Field workflow, implement monitoring, GNSS-linked reporting | Dust, moisture, proprietary signals, and harsh vibration |
| Mining haul truck | temperatures, pressures, engine hours, and warning states | Condition monitoring, service planning, operator display | Water ingress, connector fatigue, and severe shock |
| Municipal snow plow | engine data, hydraulic controls, spreader status, location | Route reporting, material usage, winter operations | Mixed protocols, corrosion, cold-start voltage drops |
For on-road CAN bus fleet management, the rugged tablet may combine dispatch, navigation, driver forms, and vehicle diagnostics in one mounted device, so buyers should apply the same evaluation criteria they use when choosing a rugged tablet for fleet management. For off-highway equipment, the same tablet may be used as a maintenance screen, operator terminal, or data logging node that survives dust, vibration, and outdoor temperature changes.
Vehicle Power, Grounding, and Wide-Voltage Risks
Quick Answer: Many CAN communication failures in real deployments are caused by unstable vehicle power, poor grounding, voltage transients, EMI or wiring faults rather than by the can protocol itself. Power design must be validated with the dock, tablet, CAN transceiver and vehicle harness together.
Vehicle-mounted rugged tablets often operate from a wide-voltage DC input through a dock or power module. Mixed fleets may include 12 V, 24 V, and sometimes higher-voltage auxiliary environments, so common designs use ranges such as 9–36 V or 10–60 V with ignition-sense control, especially in deployments that use vehicle-mounted tablets for fleet management across different industries and duty cycles.
A vehicle electrical system can be harsh. Cranking can pull voltage down, heavy motors can inject noise, reverse polarity can occur during installation, and load dump events can create severe voltage spikes; one vehicle power paper reports that a 24 V system load dump pulse can exceed 170 V in some conditions.
The physical layer depends on stable signaling and a reliable reference environment. The CAN bus uses a twisted pair wiring configuration with a characteristic impedance of 120 ohms and requires termination resistors at both ends of the bus to minimize reflections and ensure signal integrity.
A CAN transceiver reads the differential voltage between CAN_H and CAN_L, which helps the system operate in electrically noisy environments. The system is extremely robust against electrical disturbances and electromagnetic interference, making it ideal for safety-critical applications such as vehicles.
Robust does not mean indestructible. Poor grounding, long stubs, shared returns with high-current loads, noisy DC/DC converters, incorrect shielding, and bad connector bonding can still create intermittent errors.
For system integrators, the practical checklist is clear: validate ignition-sense wiring, document the vehicle power diagram, use transient-protected power supplies, avoid routing CAN cables parallel to alternator or motor wiring, and confirm the dock, tablet, and vehicle chassis share a clean ground reference. EMI, grounding, and transient protection should be treated as deployment requirements, not optional accessories.
Docking Stability and CAN Communication Reliability
Quick Answer: A stable vehicle dock and mount are as important as the CAN interface. Vibration, connector movement, intermittent power or unsupported cables can corrupt CAN communication and disrupt telematics workflows.
A rugged docking station gives the vehicle-mounted tablet fixed I/O, stable charging, repeatable connector alignment, and cable retention. It allows the tablet to be removed for shift changes or maintenance without rewiring the CAN interface.
Loose mounts create a different risk profile. A simple clamp may hold the tablet visually, but if a dangling CAN cable moves with every vibration event, the connector can loosen or wear. Over time, vibration can increase contact resistance, cause fretting corrosion, and create intermittent bus data gaps.
Connector reliability is especially important for forklifts, mining equipment, construction machines, and off-road trucks. Research on CAN bus connectors in mining applications has shown that even IP-rated connectors can fail when vibration, water ingress, fatigue, and corrosion combine.
Docking vs Loose Mount
| Mounting Style | Better For | Common Risk |
|---|---|---|
| Full-featured vehicle dock with CAN, power, and locking connectors | Fleet rugged tablet, rugged MDT tablet, forklift CAN tablet, heavy equipment HMI | Requires planned installation, correct harness, and dock selection |
| Simple cradle or clamp with external CAN adapter | Short pilot, temporary diagnostics, maintenance testing | Cable fatigue, loose connector, intermittent power, and poor strain relief |
| Custom bracket with rugged dock | High-vibration forklift, mining, or agriculture vehicle | Must be validated for vibration, reach, cable bend radius, and serviceability |
| Consumer-style holder with dangling cable | Not recommended for industrial CAN workflows | High risk of failed data transmission during vibration |
KCOSIT vehicle dock and mounting options should be selected according to vibration exposure, cable retention, power input, CAN interface location, serviceability, and the target vehicle workflow, in the same way that rugged tablets for the defense industry must be matched to mission profiles and extreme operating conditions.

Common CAN Bus Integration Problems in Rugged Tablet Deployments
Quick Answer: Most rugged tablet CAN problems fall into protocol mismatch, baud-rate errors, wiring and termination faults, grounding noise, ECU access restrictions, unstable power or poor docking. These issues should be found during validation, not after fleet rollout.
Common protocol problems include expecting J1939 but finding proprietary CAN, assuming OBD-II PIDs are available on a heavy truck, or buying CAN FD hardware when the exposed fleet connection is still classical CAN. A single CAN system may be simple, but many modern vehicles include multiple networks and gateways that filter traffic.
Physical-layer problems are equally common. Reversed CAN_H and CAN_L, missing 120 ohm termination, excessive cable stubs, poor shielding, incorrect connectors, and splices made without OEM guidance can all create unstable communication.
A frame format mismatch can also stop decoding. For example, 11-bit and 29-bit identifiers are not interchangeable, and the software must understand whether a message is standard CAN, extended CAN, J1939, OBD-II on CAN, or OEM-specific.
At the software level, ECU access can be restricted. Some gateways expose only a filtered data stream, some ECUs require authentication for service functions, and proprietary signals may require OEM DBC files. This is why a CAN diagnostics tablet project should verify required signals before procurement.
Security should also be considered. Because classic CAN was built for trusted in-vehicle networks, not open internet-connected environments, integrators should protect the telematics tablet, restrict write functions, manage application permissions, and avoid unnecessary transmit data on the bus.
| Risk Area | Common Problem | Better Validation |
|---|---|---|
| Protocol mismatch | Vehicle exposes J1939, OBD-II, proprietary CAN, or filtered gateway data | Verify protocol and required signals on real vehicles |
| Baud rate mismatch | The tablet or gateway listens at the wrong speed | Test 250 kbit/s, 500 kbit/s or project-specific settings |
| Gateway filtering | Required data is not exposed | Confirm ECU access and gateway permissions |
| Power instability | Cranking or voltage dips interrupt the tablet or CAN interface | Test startup, shutdown, and ignition-sense behavior |
| Grounding / EMI | Noise creates intermittent data loss | Validate grounding, shielding, and cable routing |
| Dock vibration | Connector movement causes data gaps | Test dock retention on real routes or work cycles |
| Software decoding | Raw frames are available, but not usable | Confirm DBC, PGN/SPN, PID, or OEM mapping |
| Replacement units | The spare tablet or dock behaves differently | Validate firmware, OS image, driver, and cable consistency |
In real vehicle deployments, CAN communication problems are often caused by integration assumptions rather than by the CAN protocol itself. Fleet validation should test the complete workflow, including the rugged tablet, dock, power input, CAN adapter, vehicle gateway, operating system, firmware, and application behavior together.
How to Validate CAN Communication Before Fleet Rollout
Quick Answer: Successful CAN bus rugged tablet projects use staged validation across representative vehicles before large-scale deployment. Bench testing alone is not enough because real vehicles add vibration, power transients, grounding variation, EMI and gateway behavior.
A practical validation flow has four stages:
- Bench test: tablet, dock, CAN interface, simulator, known messages, termination, and power input.
- Pilot vehicle: one representative truck, forklift, tractor, or public safety vehicle under real operating conditions.
- Small pilot fleet: 5–20 vehicles across model years, duty cycles, and environments.
- Full rollout: standardized hardware, firmware, harnesses, installation instructions, and replacement-unit process.
CAN Rollout Validation Checklist
- Identify the CAN protocol: classical CAN, CAN FD, J1939, OBD-II on CAN, or proprietary CAN.
- Validate baud rate and data rates for every target network, such as 250 kbit/s J1939 or 500 kbit/s automotive CAN.
- Confirm ignition on/off behavior and ignition-sense wiring.
- Run dock reconnect tests by removing and reinserting the tablet.
- Perform vibration tests on real routes, warehouse floors, fields, or job sites.
- Check grounding between the dock, chassis, CAN interface, and vehicle power.
- Simulate power interruption, cranking dips, and safe shutdown behavior.
- Validate ECU access, required messages, diagnostic trouble codes, and any allowed write functions.
- Verify replacement tablets and docks use the same firmware, drivers, CAN configuration, and cable layout.
Continuous data logging is important during pilot testing. The integrator should review timestamp consistency, missing frames, malformed data, decoded RPM, speed, fuel, ignition, and fault-code accuracy over several shifts or routes.
Document the validated configuration. Include cable type, connector pinout, dock model, firmware version, OS image, application version, baud rate, DBC files, and gateway settings so every later installation matches the proven design.
Procurement Checklist for CAN Bus Rugged Tablet Projects
Quick Answer: Procurement teams should turn CAN integration risks into clear specifications. The purchasing request should define protocol support, voltage range, dock requirements, ECU access, software APIs, mounting design and replacement-unit consistency.
Use this checklist when specifying CAN bus rugged tablets for industrial vehicle projects:
- Required CAN protocol: CAN 2.0, CAN FD, J1939, OBD-II on CAN or OEM proprietary CAN.
- Supported maximum data rate, including 250 kbit/s, 500 kbit/s, 1 Mbit/s or higher, can fd data transfer speeds where required.
- Vehicle voltage range, such as 12 V, 24 V or wider mixed-fleet input, plus transient protection.
- Ignition-sense input for controlled startup and shutdown.
- ECU compatibility assumptions, including read-only access, write permissions, authentication, and signal availability.
- Dock type with integrated CAN interface, stable power, and locking connector options.
- Cable routing plan using twisted pair wiring, strain relief, and separation from high-current lines.
- Grounding plan for the dock, tablet, CAN interface, and vehicle chassis.
- Mounting hardware suitable for vibration, shock, driver reach, and maintenance access.
- Rugged Android or rugged Windows tablet selection based on telematics, diagnostics, or maintenance software.
- Driver, SDK or API availability for the CAN controller and application software.
- Connectivity requirements such as LTE, 5G, Wi-Fi, GNSS, Bluetooth, NFC, barcode, or RFID, where the workflow needs them.
- Security policy for ECU access, application permissions, remote management, and over-the-air updates.
- Replacement workflow so spare tablets, docks, and cables match the validated field configuration.
CAN communication is only one part of rugged tablet vehicle integration; for a broader guide to rugged tablet interfaces, docking, serial communication, Ethernet, OBD-II, and industrial connectivity, see Kcosit’s rugged tablet interfaces and protocols guide.
For CAN-focused projects, KCOSIT can help buyers evaluate vehicle-mounted rugged tablets, docks, mounting options, and interface configurations against the target CAN network, vehicle power environment, software stack, and rollout plan.

FAQ About CAN Bus Rugged Tablets
These questions cover practical issues buyers and integrators often raise after the initial CAN design is understood.
Can a rugged tablet safely write commands onto the vehicle CAN bus?
A rugged tablet should only write to the vehicle CAN bus when the vehicle OEM, ECU security model, and application workflow allow it. Arbitrarily transmitted data can interfere with control systems, so write functions should be authenticated, validated, and limited to approved service or workflow commands.
How does vibration in forklifts and off-road vehicles impact CAN communication?
Vibration can loosen connectors, damage cable strain relief, increase contact resistance, and create intermittent power or CAN signal loss. For forklift CAN tablet and off-road deployments, use a stable dock, locking connectors, short supported cable runs, and real-route vibration testing.
Do we need CAN FD support in tablets for fleets purchased between 2020 and 2026?
Not always. Many 2020–2026 heavy-duty, forklift, agriculture, and fleet vehicles still rely on classical CAN and J1939, while CAN FD appears more often in newer EVs and data-heavy platforms. Validate the exposed network before paying for CAN FD support.
What is the difference between connecting to the CAN backbone and only using the OBD-II port?
The OBD-II port usually provides a limited diagnostics view, especially on light vehicles. A backbone or OEM telematics connection may expose richer signals such as PTO, body, hydraulic, or brake data, but it also increases integration responsibility and must follow OEM guidance.
Why are docking stations important for CAN bus rugged tablets? Can
CAN bus rugged tablets depend on more than the CAN interface? Power stability, grounding, cable retention, connector alignment, and vibration control all affect whether CAN communication remains stable during real vehicle operation. A proper vehicle dock can protect the CAN connection, charging path, and cable routing better than a loose mount with exposed adapters.
Is CAN bus the same as OBD-II?
No. CAN bus is the vehicle communication network, while OBD-II is a diagnostic access standard used mainly on light-duty vehicles. Many OBD-II systems use CAN underneath, but OBD-II usually exposes only a limited diagnostic view rather than every vehicle signal.
Can one vehicle-mounted rugged tablet support CAN, OBD-II, and J1939?
It may support multiple vehicle communication workflows if the tablet, adapter, dock, driver, and software stack are configured for them. Buyers should verify each target vehicle type, connector, protocol, baud rate, and data field before fleet rollout.